Generalist robot policies have advanced by learning from large collections of observations and actions. Vision-language-action models (VLA) connect semantic understanding to control; world-action models (WAM) add learned physical dynamics. Both routes put new competence into model parameters through training, and that trained prior is what a robot leans on when an unfamiliar task arrives.
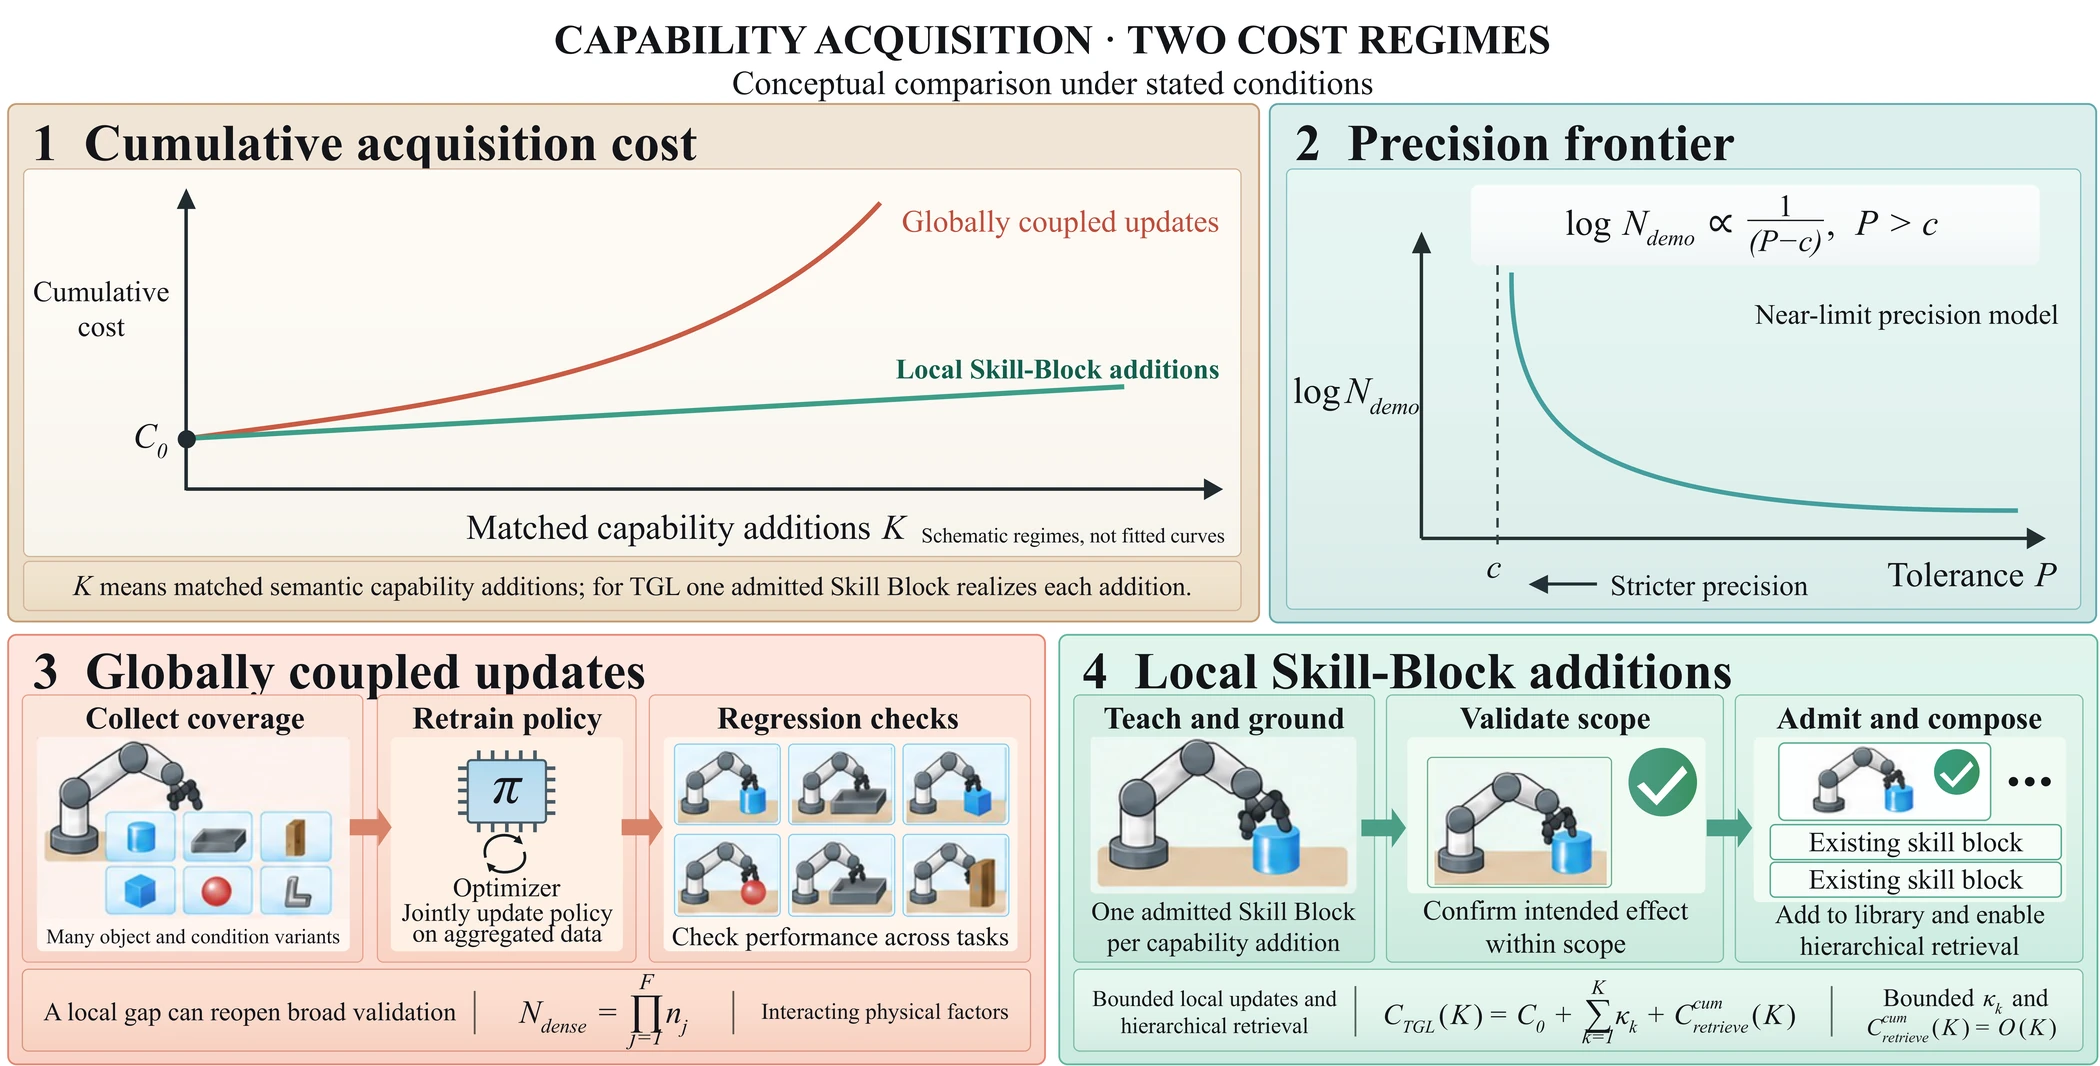
Physical interaction data has a different cost structure from text or code. Most of it exists only after a robot or simulator has been run: contact has to be observed, a grasp has to be tried, a collision risk has to be recovered from, and the actual change has to be checked. Object pose, camera geometry, clutter, material, and embodiment also interact, so covering one factor does not cover their combinations.
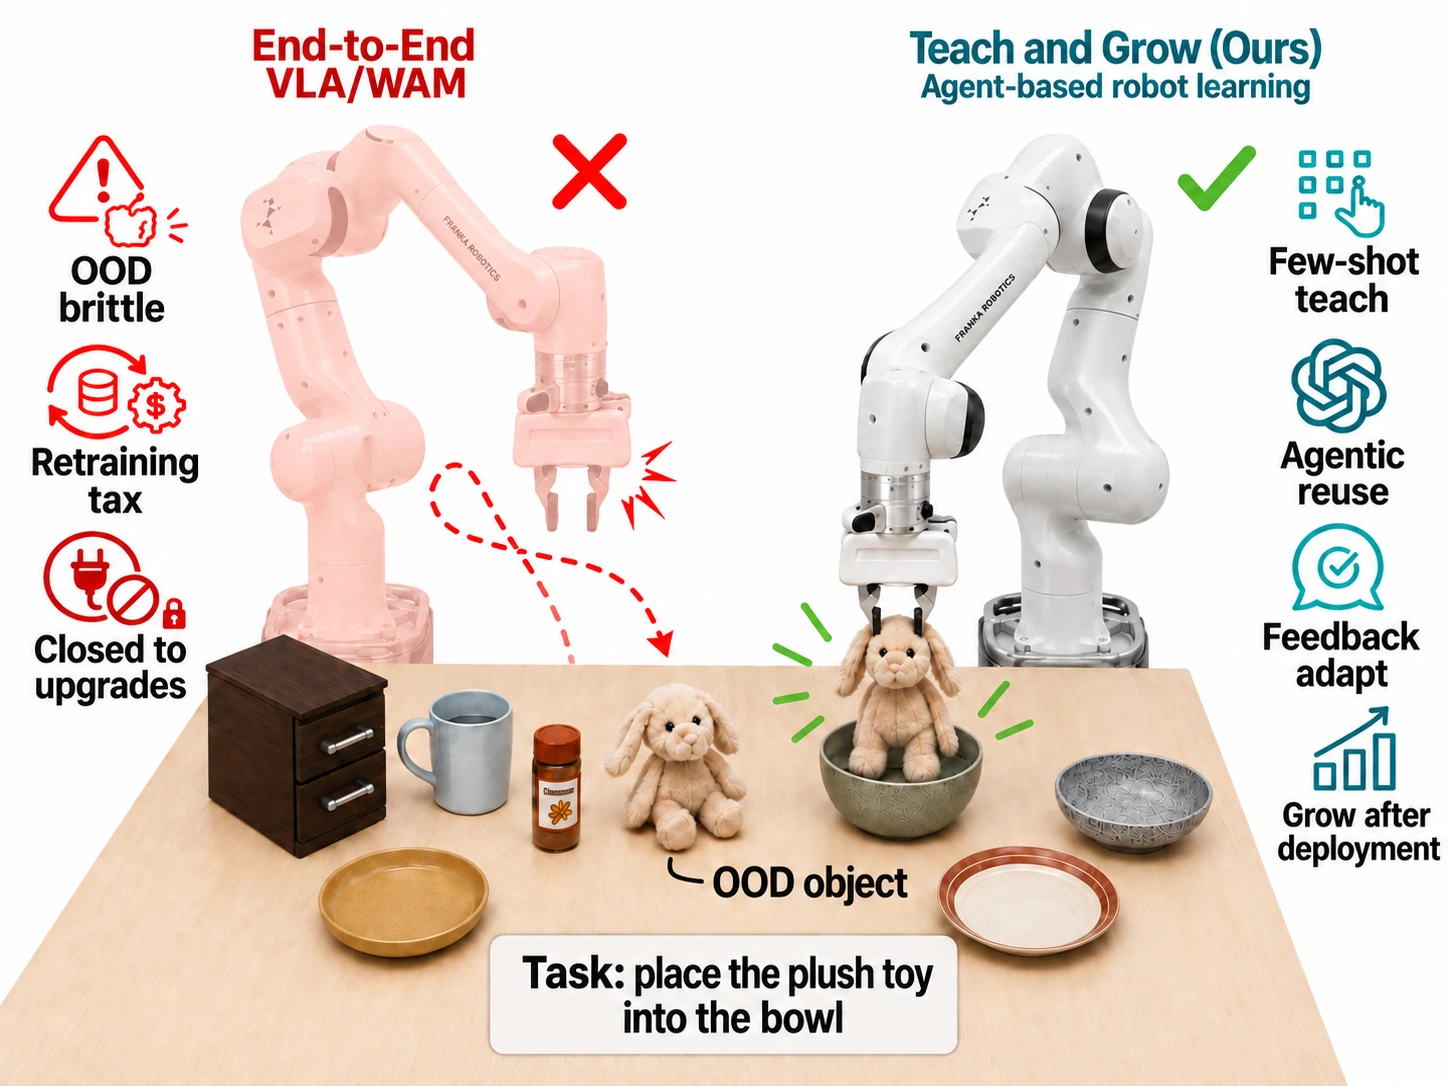
Repairing a failure through a policy update usually means new data collection, another optimization run, and regression checks on everything the policy already supported. We call this recurring burden the retraining tax. It shows up most clearly in the long tail, where a rare contact condition or an unusual object needs one specific lesson rather than another broad round of experience.
The repair is also hard to keep local. If a VLA fails to retain an unfamiliar bowl, corrective data and updated parameters do not leave behind a separately addressable “bowl-retention fix”; the change spreads through the weights, and earlier behavior has to be checked again. A new sensor or gripper repeats the problem at the interface, where observation format, calibration, and action compatibility all need validation.
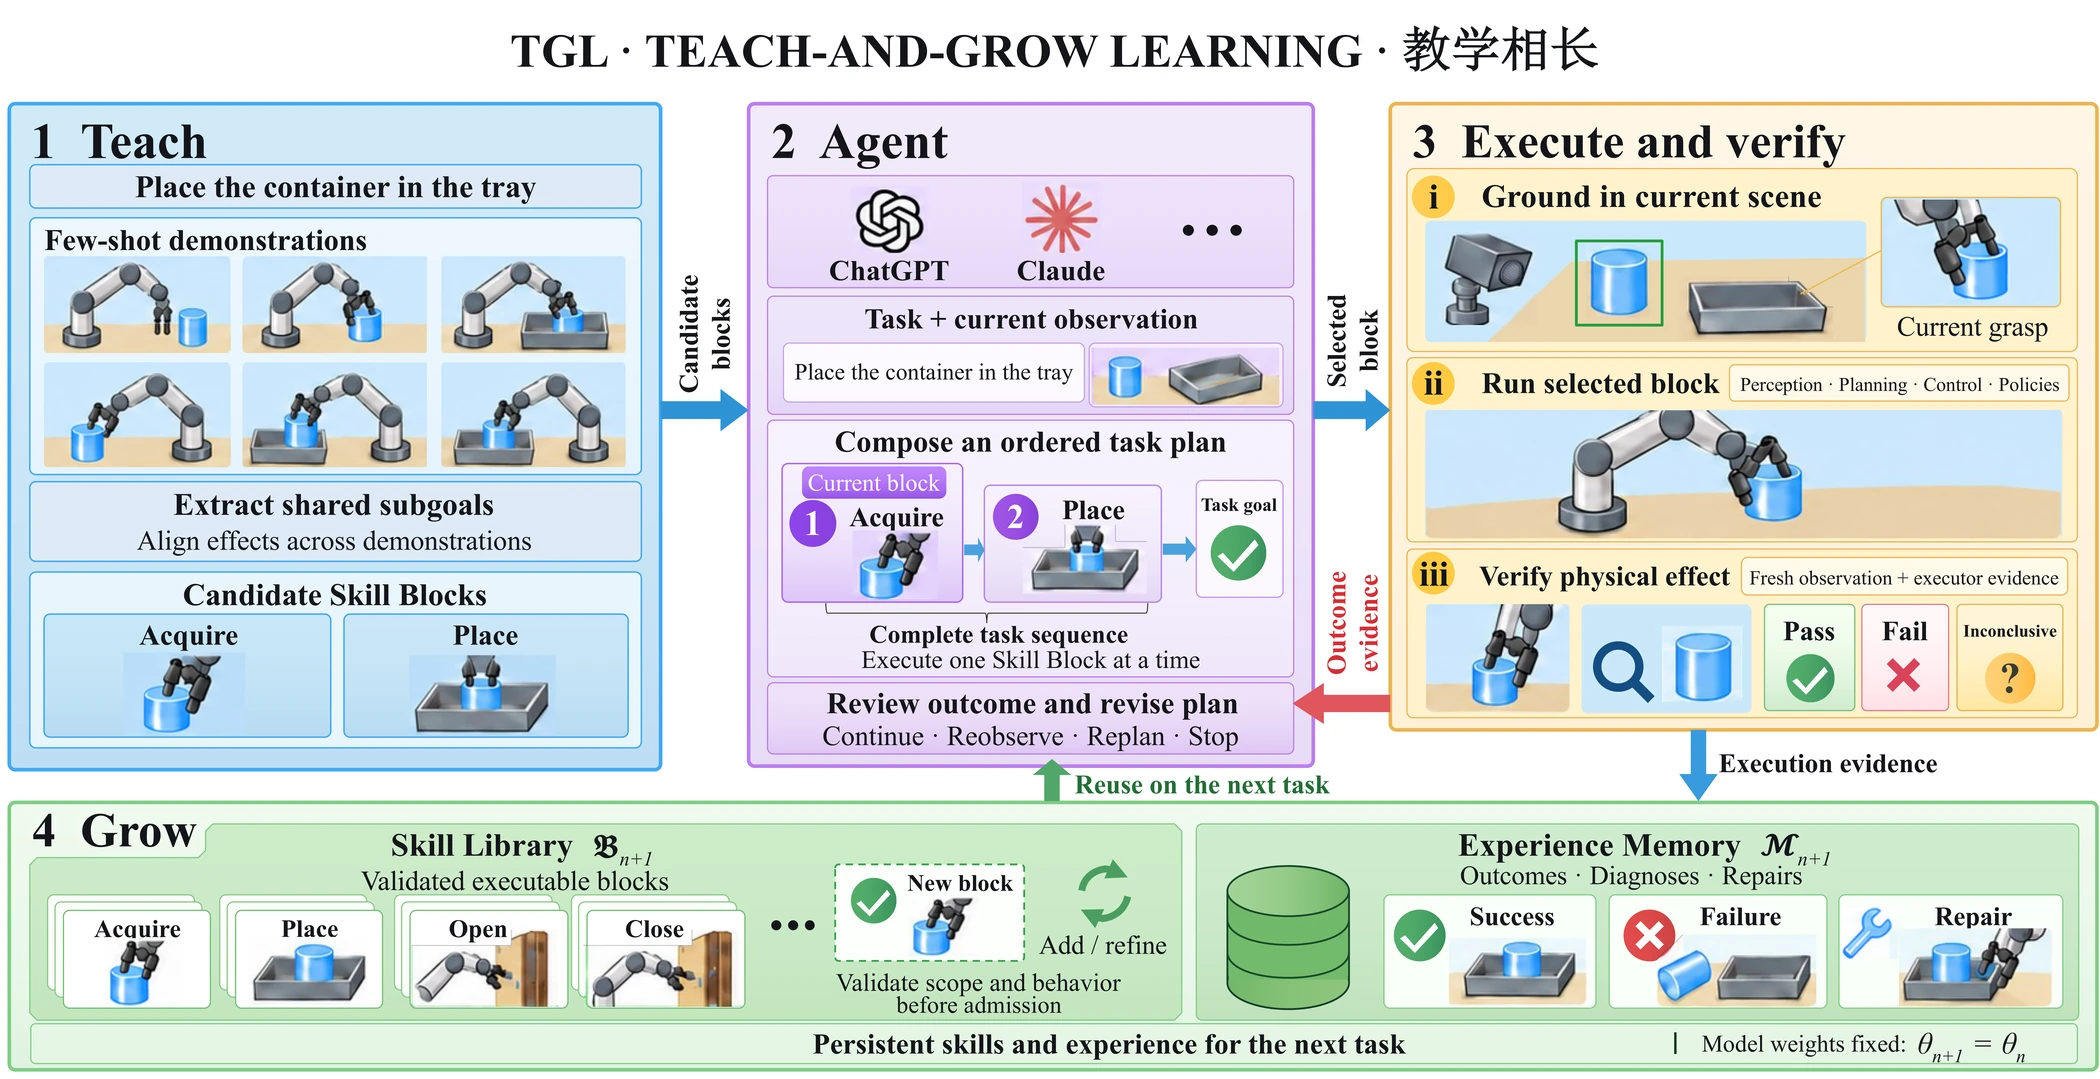
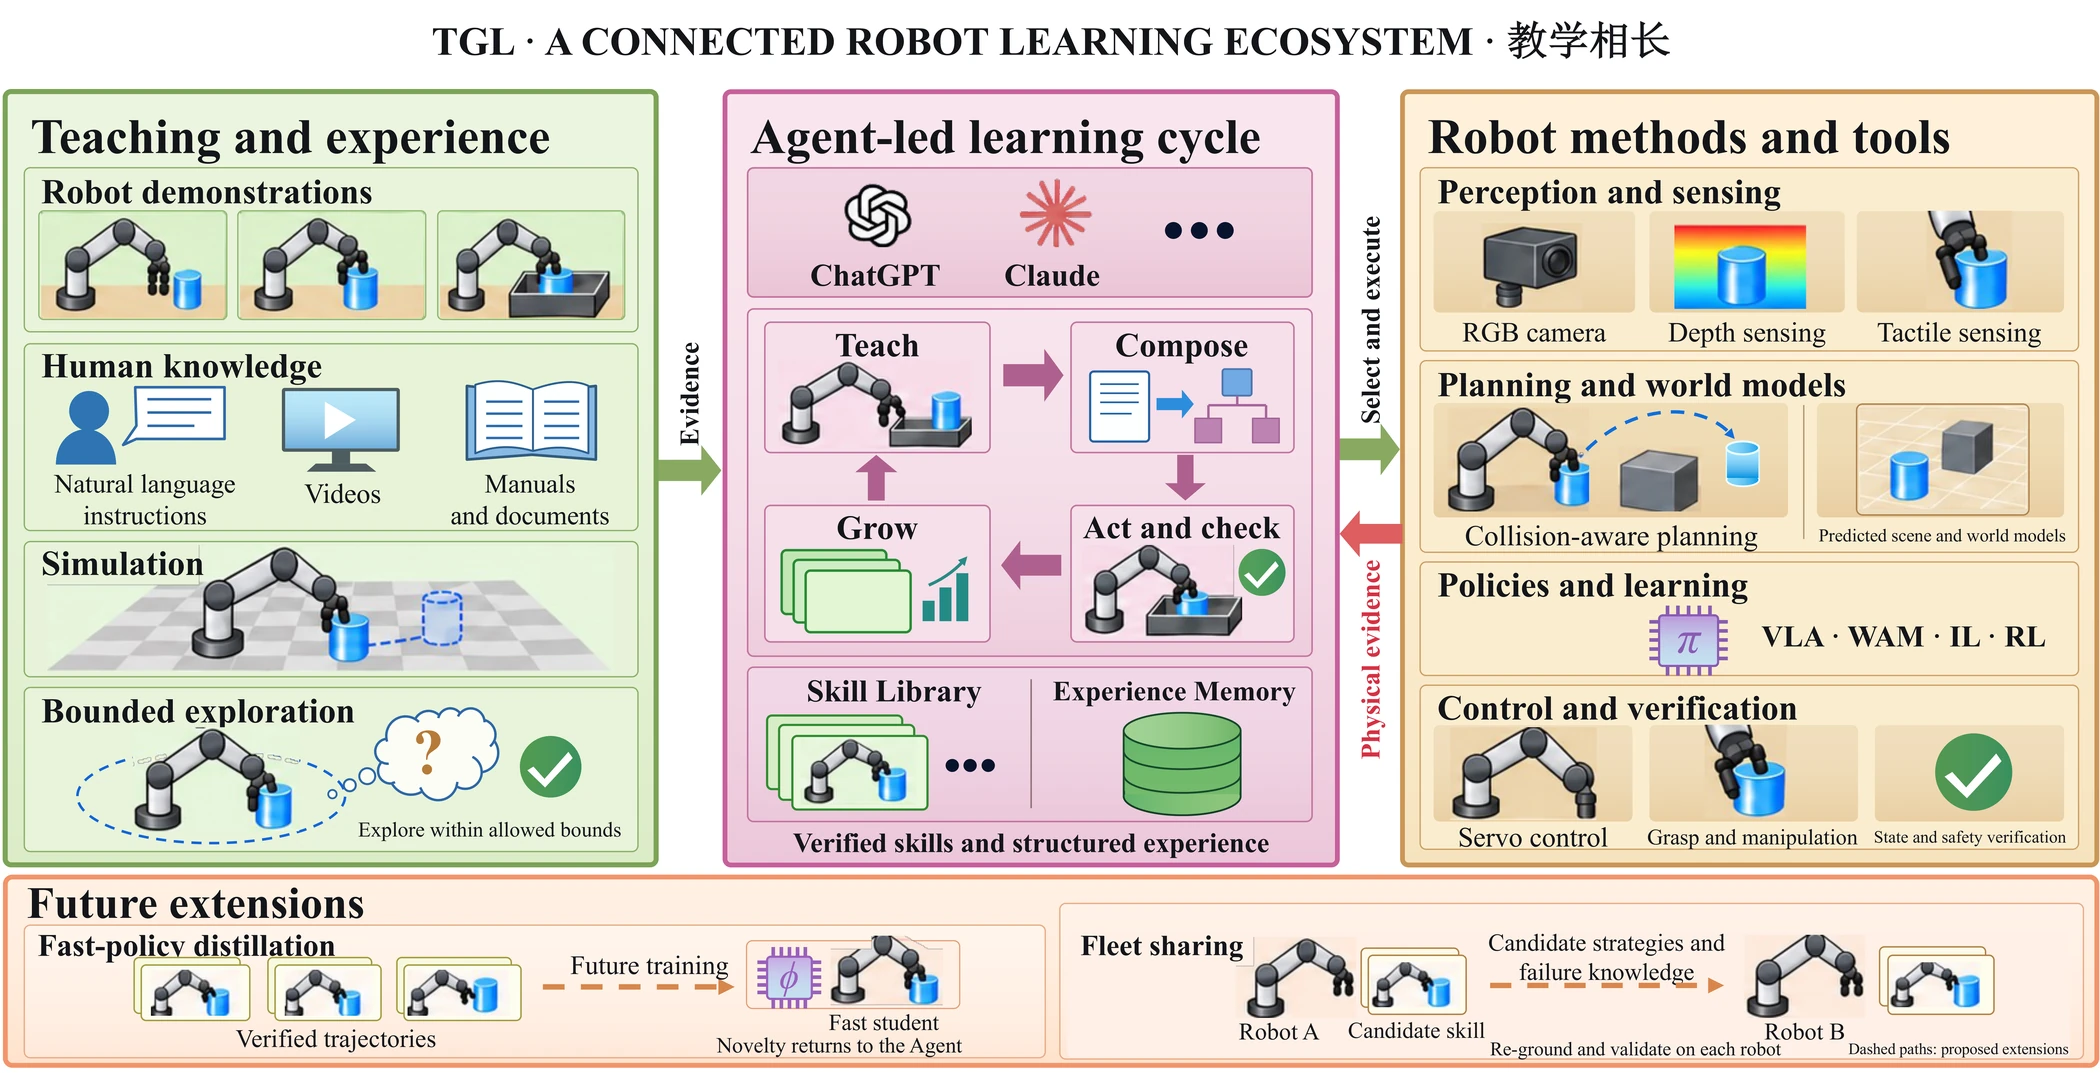
Long-tail experience is also hard to turn into a reusable correction. A successful trajectory may say nothing about the conditions that mattered after the failed grasp, and when the lesson lives only in parameters, the failure condition, the recovery rule, and the supported scope cannot be inspected or revised one at a time. TGL starts from that question: can a robot keep those objects explicit, and update only the behavior that is affected?